
 Kontakt
 Wie einkaufen

Versand
Kaufberater
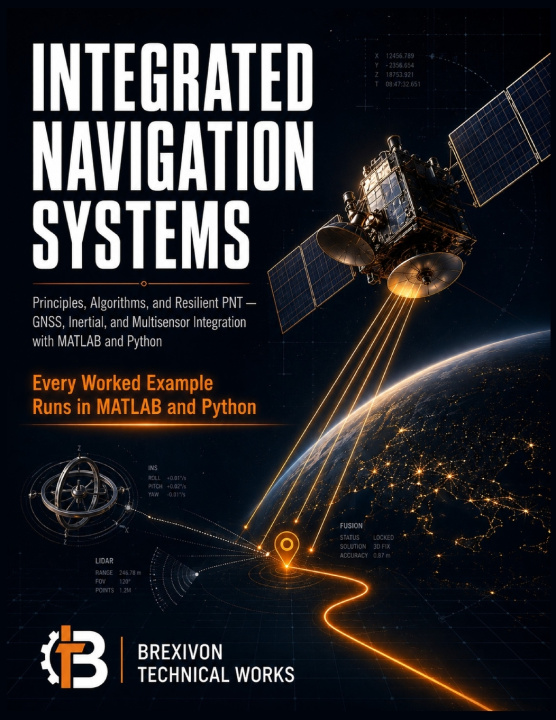
Integrated Navigation Systems
Principles, Algorithms, and Resilient PNT: GNSS, Inertial, and Multisensor Integration with MATLAB and Python
 Englisch
 225 b
Bis zu 30 Tage Rückgaberecht
Kunden kauften auch


A single jammer the size of a cigarette lighter can take down GPS for everything within a mile. So why does almost every navigation textbook still stop at the clean-sky case?
Real vehicles - aircraft, autonomous cars, drones, ships, robots - don't operate in a laboratory. They lose satellites in urban canyons, drift when the inertial unit is left to run alone, and face interference that is now cheap, common, and sometimes deliberate. Positioning that survives the real world isn't one sensor done well. It's many sensors, fused correctly, with a system that knows when to trust each one.
Integrated Navigation Systems is the graduate-level reference and practitioner's handbook for building exactly that. It develops modern Positioning, Navigation, and Timing (PNT) from first principles all the way to resilient, multisensor systems - and it does it the way an engineer actually learns: derivations you can follow line by line, worked examples solved in full, and code you can run.
What makes this book different
Most texts teach a single technique in isolation. This one teaches integration - how GNSS, inertial navigation, and complementary sensors combine into a system that stays accurate when any one of them fails. You move from reference frames, inertial mechanization, and GNSS positioning through the estimation core (Kalman filtering, error-state formulations, factor graphs, and nonlinear optimization), then into loosely and tightly coupled GNSS/INS integration, all-source fusion, and visual, LiDAR, and radar-inertial odometry and SLAM. The final chapters take on what most books avoid entirely: integrity monitoring and ARAIM, resilience against jamming and spoofing, alternative PNT from LEO constellations and signals of opportunity, and full system design, testing, and reference architectures.
Learn it by running it - in both MATLAB and Python
Every worked example is implemented in both MATLAB and Python, so you can read whichever you know and pick up the other. The code isn't a screenshot - it's a free, maintained online companion of runnable scripts, one for every example, written to be modified: change a sensor grade, a noise level, or a geometry, and watch the estimator respond. That's how the intuition behind a filter actually forms.
Built for people who need to get it right
Clear derivations with every variable and unit defined. Worked examples with boxed final answers. Practice problems with worked answer keys at the end of each chapter. Reference tables of the constants, frames, and design values you reach for constantly. It's written to be studied cover to cover and kept on the desk afterward.
This book is for you if you are:
- A graduate student or advanced undergraduate in aerospace, robotics, geomatics, or electrical engineering
- A navigation, guidance, controls, or autonomy engineer building or integrating PNT systems
- A researcher or developer working on drones, self-driving vehicles, or robotic platforms
- An engineer who already knows one piece - GNSS or inertial or estimation - and needs to see how they fit together
You should be comfortable with calculus, linear algebra, and basic probability. From there, the book builds everything else.
GPS was never meant to be trusted alone. Learn to build navigation that holds when it can't be. Scroll up and start reading today.


Informationen zum Buch
Englisch

Verschenken Sie dieses Buch noch heute
Es ist ganz einfach
1 Legen Sie das Buch in Ihren Warenkorb und wählen Sie den Versand als Geschenk 2 Wir schicken Ihnen umgehend einen Gutschein 3 Das Buch wird an die Adresse des beschenkten Empfängers geliefertDas könnte Sie auch interessieren


Hallo! Ich bin Libroamiko, dein Buchberater.
Wie kann ich dir helfen?